Hey, I'm Anas 👋
I'm building robots
that save lives.
I'm a robotics and AI engineer, and I want my work to matter — machines that go where people can't, find survivors, and bring them home. That's the mark I'm trying to leave: technology that saves lives.

Experience
Where the
work happens.
Two TÜBİTAK-funded projects at Fırat University's RAI Laboratory — SLAM pipelines, deep RL navigation and embedded AI, taken from simulation to real hardware. Now continuing with deep RL for multi-robot navigation at ISR-Lisboa.

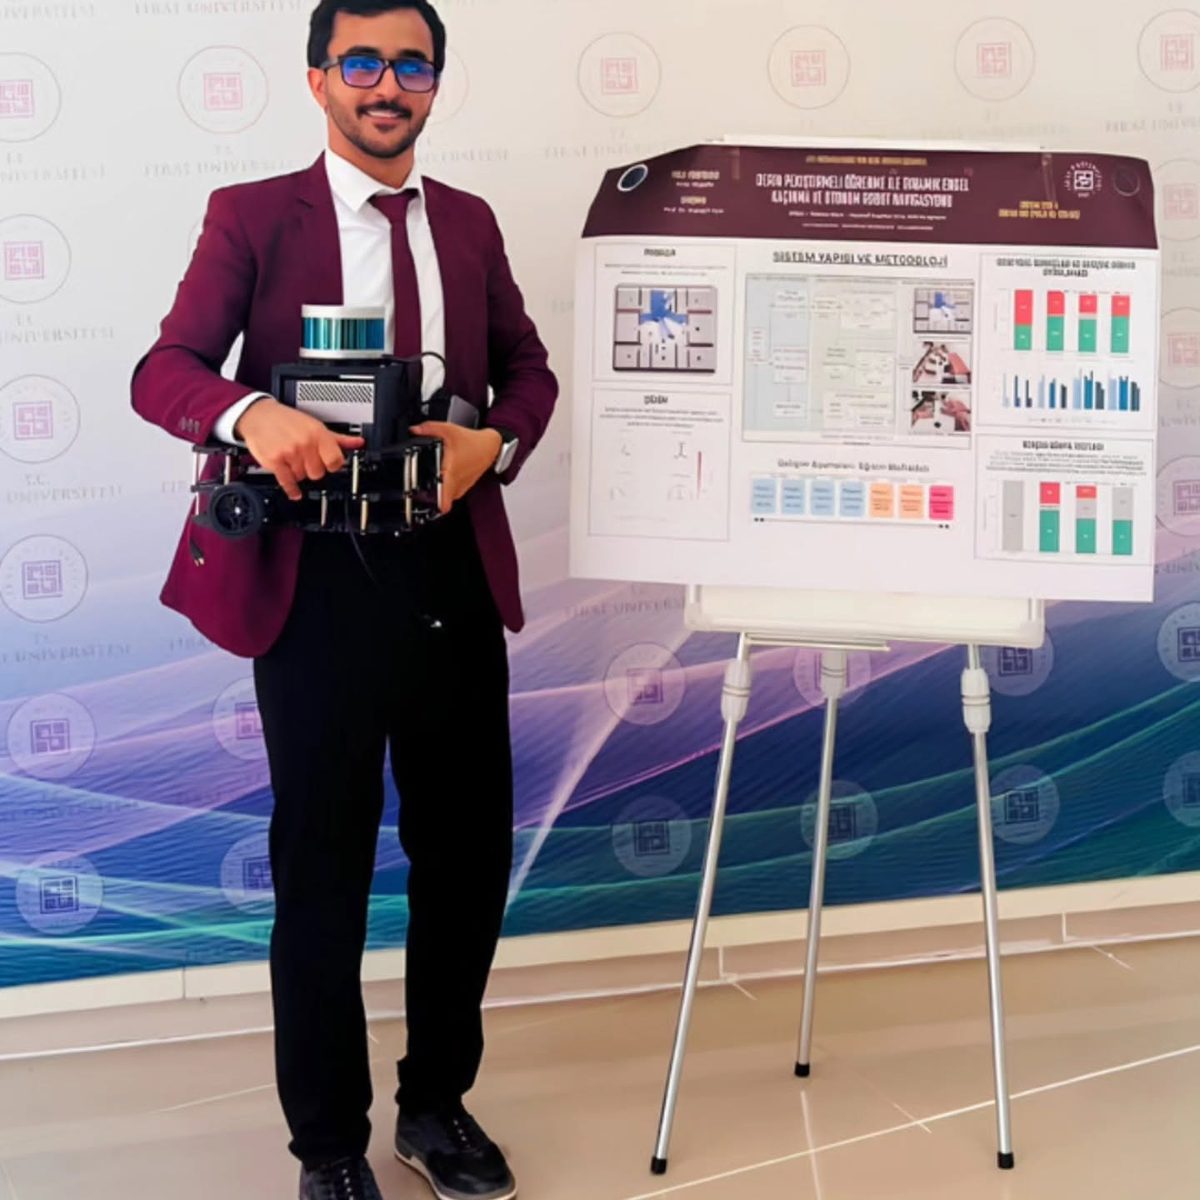
Our GPS-denied mapping rig — LiDAR, IMU & Jetson
ISR-Lisboa · Instituto Superior Técnico
Sept 2026 – nowResearch Intern — Autonomous Systems
Deep reinforcement learning research on autonomous and multi-robot navigation in Prof. Pedro Lima's group. Part-time and hybrid, alongside my M.Sc.
TÜBİTAK 1001 · RAI Lab
Jul 2025 – May 2026Robotics & AI Researcher
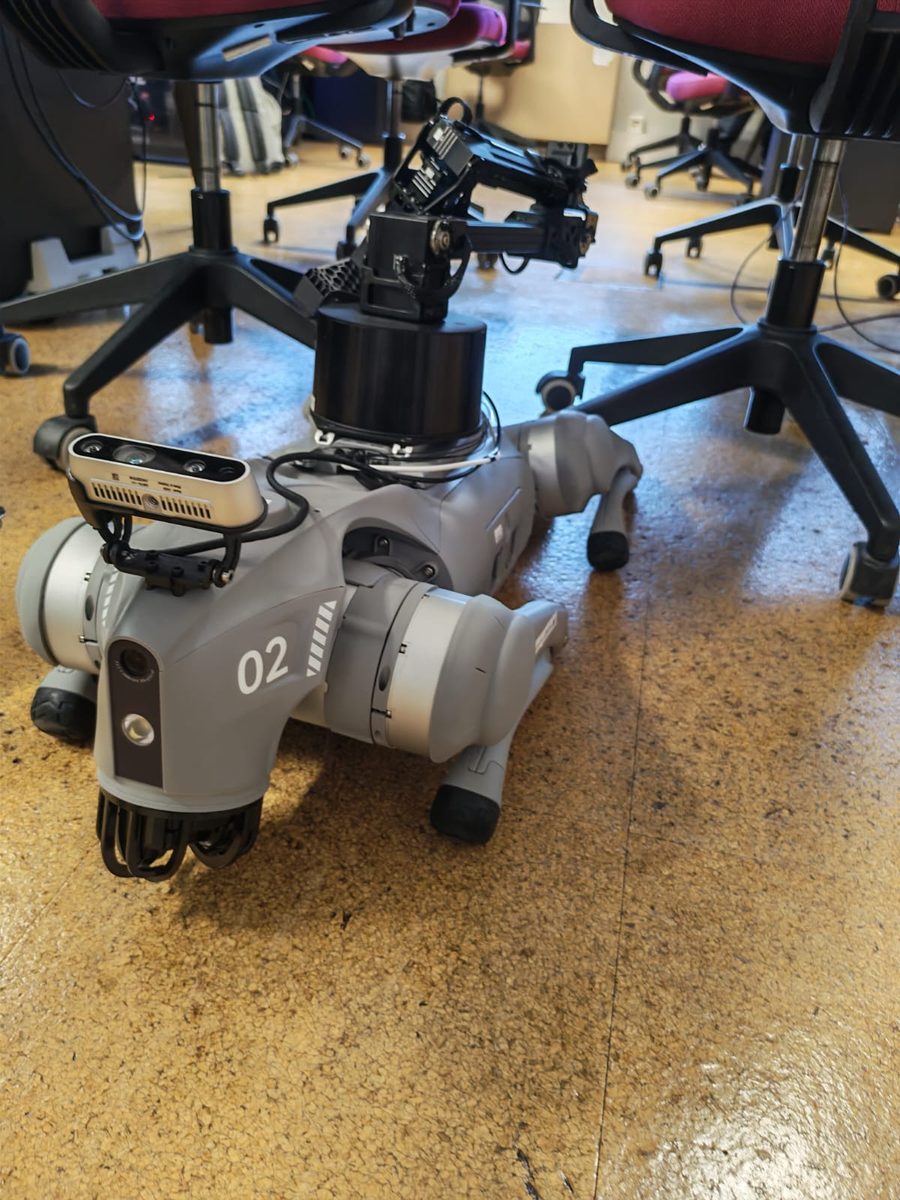
Integrated a Unitree Go2 quadruped, Velodyne VLP-16 LiDAR, RGB-D camera and Pixhawk onto one Jetson Orin platform, and built ROS 2 LiDAR-inertial odometry and 3D SLAM (RKO-LIO) for GPS-denied zones. Grant 123E406; I first joined the lab as a summer intern in 2024.
TÜBİTAK 2209-A · Principal Investigator
May 2025 – Jul 2026Autonomous Navigation System
Secured a national grant and led it end to end: deep reinforcement learning (SAC/PPO) + SLAM on TurtleBot3 and Jetson AGX Orin, with a three-stage curriculum from Gazebo to the real robot. Results published in Applied Sciences.
Drift-Resilient Indoor 3D Mapping in GPS-Denied Environments Using RKO-LIO with Velodyne–Pixhawk Integration in ROS 2
Alqadhi, A. M. N. S., Bajhaw, M. A. M. S., El Muhammed, M., & Ucar, A. (2026).
RKO-LIO fuses Velodyne VLP-16 LiDAR with a Pixhawk IMU on Jetson AGX Orin for drift-resilient indoor 3D mapping in GPS-denied environments — SLAM research with direct applicability to disaster response and defense robotics.
PV-STAM: Velocity-Aware Attention for Mapless Deep Reinforcement Learning Navigation in Dynamic Environments
Alqadhi, A. M. N. S., El Muhammed, M., Bajhaw, M. A. M. S., & Ucar, A. (2026). Applied Sciences, 16(18), 9083. Project page → Code DOI
MSR-SLAM: A Multi-Stage Map-Refinement Framework for Reliable LiDAR-Inertial SLAM in GPS-Denied Environments
El Muhammed, M., Alqadhi, A. M. N. S., Bajhaw, M. A. M. S., & Ucar, A. Applied Sciences — minor revision.
Honors
The wins that mattered most.
2
First-Author Papers
IEEE ICHORA 2026 (oral, Ankara) and Applied Sciences, 2026.
1st
Faculty Final-Project Expo
Ranked first among graduating projects, June 2026.
Finalist
TEKNOFEST & TÜBİTAK 2242
National finalist, university research-project competition, 2026.
3rd
YDDD National Engineering Competition
Undergraduate category · Creativity & Innovation Shield, 2025.
PV-STAM — Velocity-Aware Robot Navigation
A small attention block that lets a deep RL policy see whether obstacles are moving, from a single 2D LiDAR. Published in Applied Sciences and tested in 130 real-robot trials; the code, data and trained policies are public on the RAI Lab GitHub.
ROS2–YOLO–LiDAR Sensor Fusion
YOLO object detection fused with LiDAR depth projection — a distance-aware, multi-sensor perception pipeline built on ROS2.
3D ReMaker — Multifunctional Machine
Converted a broken 3D printer into a 3D printing + laser engraving + paper drawing system — a mechatronics class project.
 Read case study
Projects
Built from first principles.
A published navigation method with open-source code, multi-sensor perception, and a broken 3D printer rebuilt into three machines — taken from simulation to real hardware.
Tech Stack
Technical Skills
AI & Machine Learning
Robotics & Systems
Hardware
Languages
Background
Education & Credentials
Certifications
Journey
From scholarship to the lab.
Gallery
A few good days.
Proof that the robots occasionally cooperate.
The moment after ranking 1st — an on-camera interview at the faculty exhibition
Moments
Fırat University, 2025 – 2026



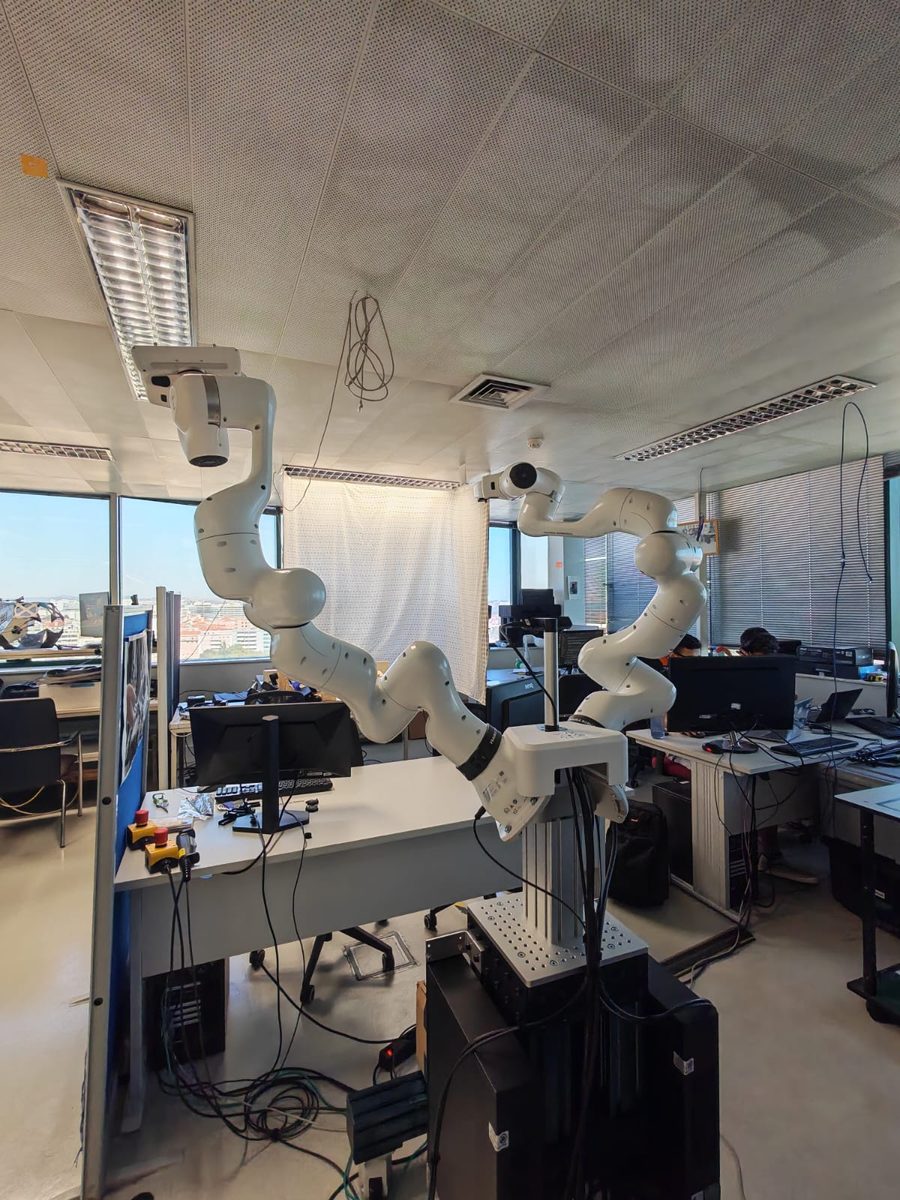
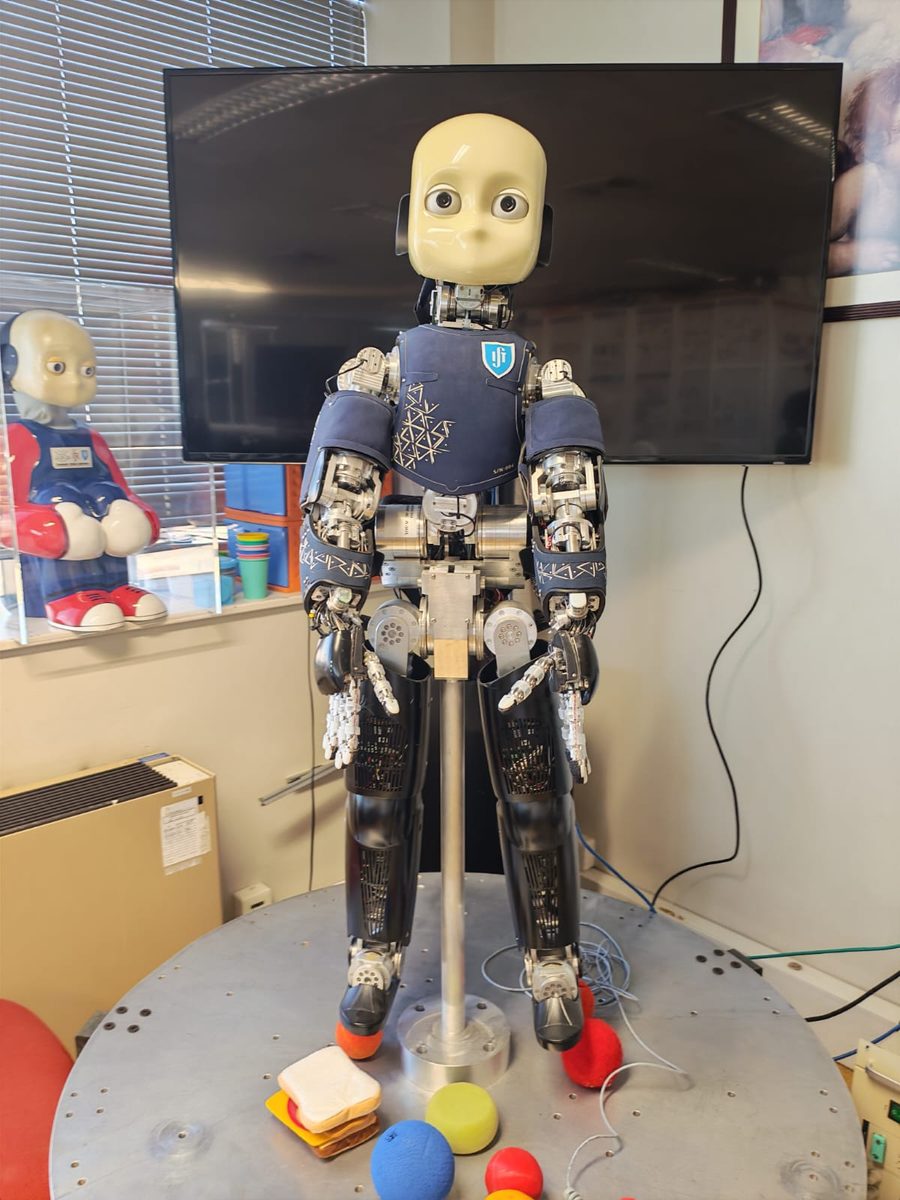
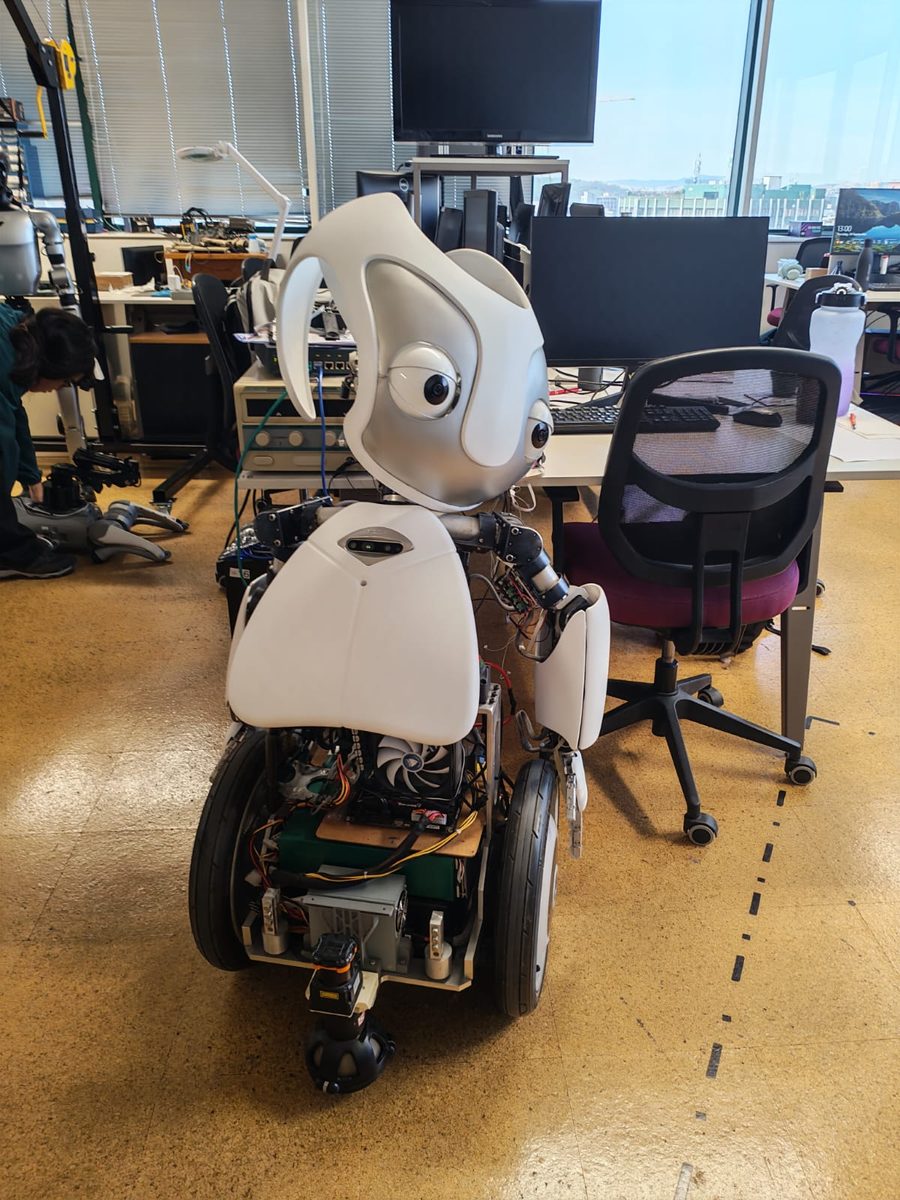
Lisbon
ISR-Lisboa · Instituto Superior Técnico, autumn 2026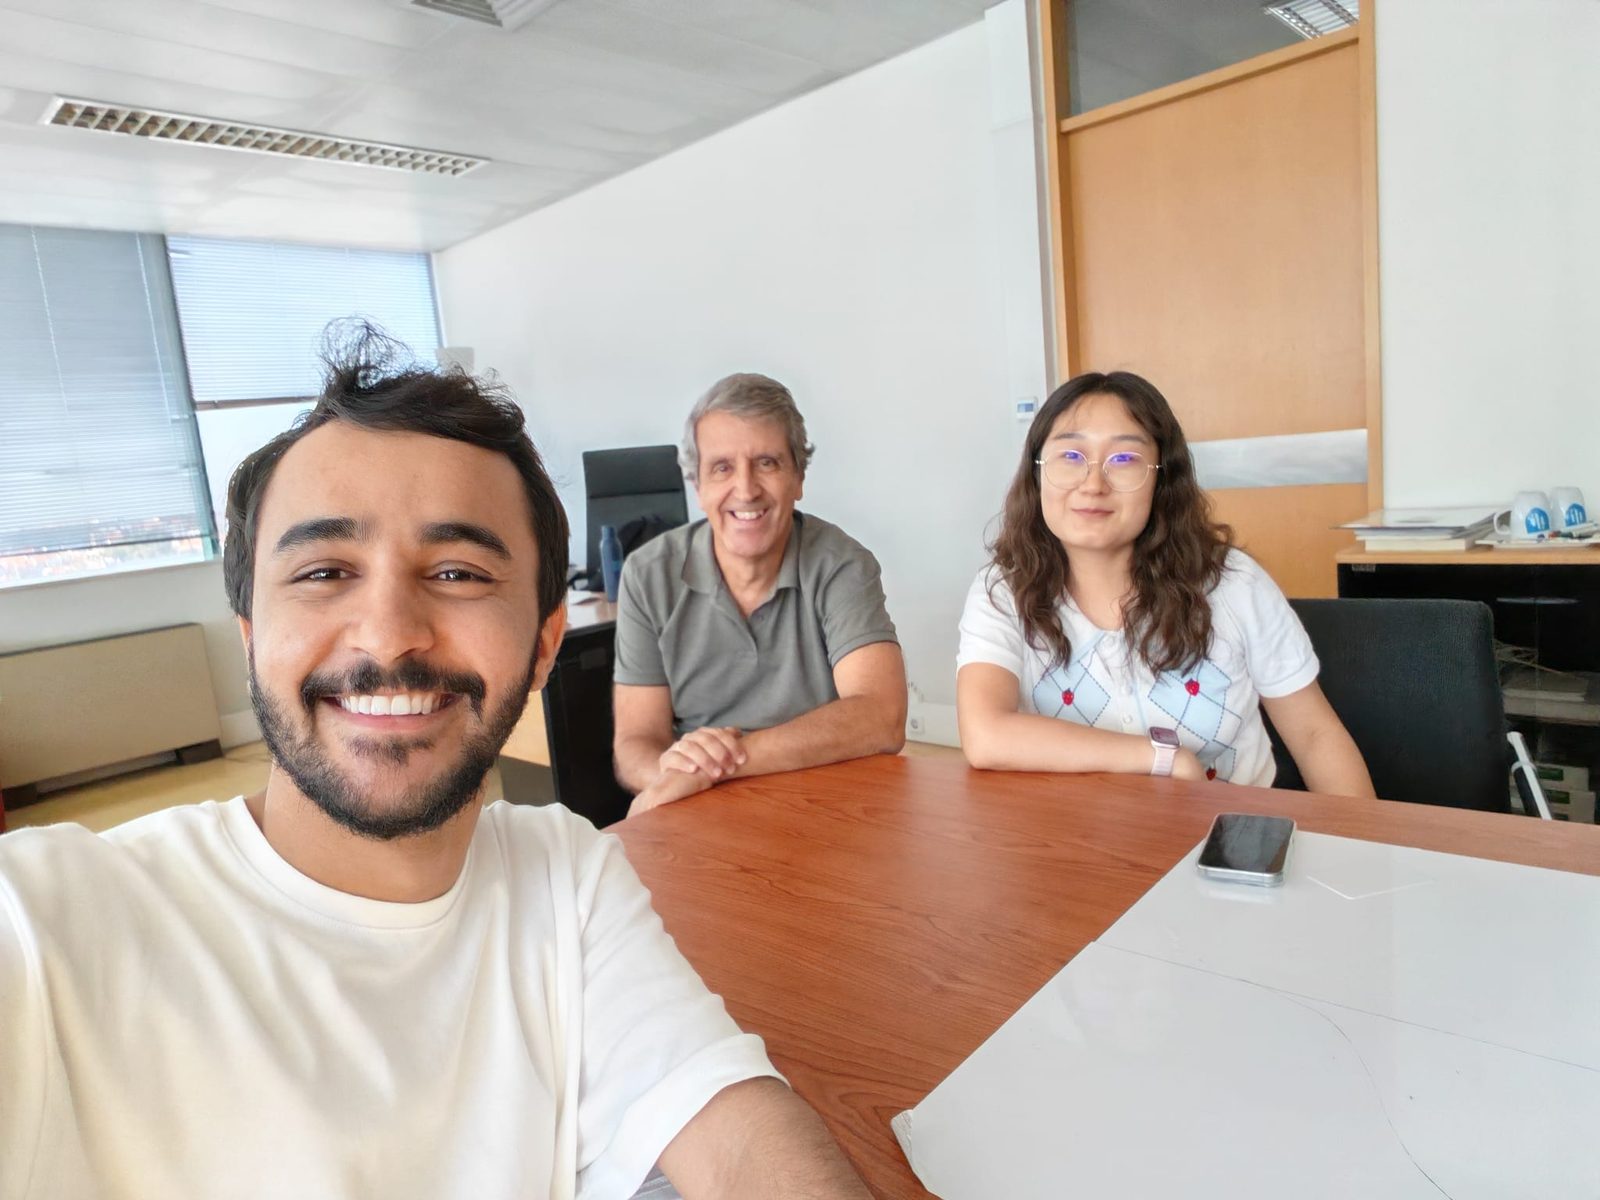
Contact
Let's build something
worth building.
Recruiter, researcher, or just curious about the robots — send me a message on LinkedIn. Based in İstanbul, researching with ISR-Lisboa.
Message me on LinkedIn